

Tutorials
These two tutorials cover the most common goals in NexCore. Each one explains when to use it, what to prepare, where to start, every step, what to expect, how to confirm you're done, common issues, and what to do next. You can follow the full workflow without a platform account.
| Tutorial | Your goal | What you get | Primary roles |
|---|---|---|---|
| A · From Raw Data to Annotated Data | Turn raw recordings into data with structured annotations and download it | Annotated data (HDF5 / LeRobot) and an export manifest | FAE, R&D engineer, data owner |
| B · From Raw Data to a Robot Model | Train a model on your own demonstrations that runs on a real robot | Model version, model artifacts, and a deployment record | FAE, R&D engineer |
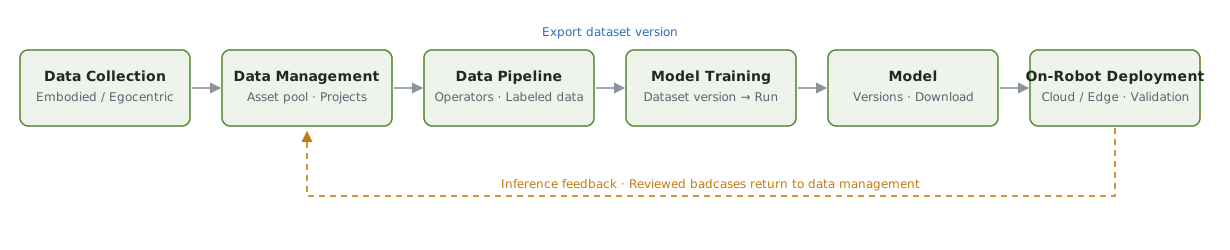
The tutorials cover different parts of this workflow: Tutorial A covers collection → data management → data pipeline, while Tutorial B runs from collection all the way to model training and deployment.
Example Conventions
Task names, device SNs, data IDs, and values in the tutorials are examples for illustration only. Your platform will show your own values.
| Item | Value |
|---|---|
| Example task | Place a cube in a box (pick and place) |
| Teleoperation device | Station Lite, SN ST-2609-0001 |
| Robot-free device | Robot-free UMI, SN NU-2609-0012 |